Every essay — page 48
What light is What the eye does Matching and measuring Difference and uniformity What the brain does What a scene does What a camera does Where the model breaks What it takes to deliver it
SeriesObserversNamed objectsRefutationsSearch
What a camera does
A camera is three functions of wavelength collapsing a spectrum onto three numbers, which is what an eye is — and they are different three functions. Everything a photograph can and cannot establish about colour follows from that, and from the fact that silicon sees three hundred nanometres past where anybody is looking.

LEDs built on the locus still fall off the line
A camera's colour error under a lamp can be estimated from three narrow channels of a small sensor, read as departures from a smooth lamp of the same colour, and the estimate held for the census's white LEDs, which varied only their blue pump. Rebuilt on LEDs varied freely in pump, converter and red phosphor, it failed: the error was a V about the Planckian locus, and no line in the departures read it. A maker does not let the white fall where it falls, so the proposal was to build the LEDs as a maker does — the converter tuned for each pump and red phosphor until the white sits on the locus — and the prediction was that the V would go and the line return, the census's held-out error to within ±0.15. Thirty of thirty-six such LEDs can be built. On the locus the V is gone and the line is not: the LEDs alone are missed by ±0.25 to ±0.28, the census's lamps by ±0.27. Taken one pump at a time, the departures read the LEDs pumped at 452 nm to ±0.05 and those at 440 and 465 nm no better than ±0.17. Within one pump the LEDs are readable, and across pumps they are not.

A channel at each pump cannot see the recipe
Thirty white LEDs built onto the Planckian locus defeat a line in a small sensor's three departures, except within one pump: the 452 nm LEDs are read to ±0.047 by the 450 nm channel, the others no better than ±0.15. The proposal was a channel at each pump — 440 and 465 nm beside the 450 — and the prediction that each pump's LEDs would be read from their own channel within ±0.08. The 465 nm LEDs' own channel halves their miss, to ±0.135; the 440 nm LEDs' moves it from ±0.171 to ±0.149. No line in any three of the five departures reads either pump better than ±0.1. Yet the camera's error is simple: a line in what each LED is made of — its red phosphor, its colour temperature and their product — reads every pump within ±0.07, the 440 nm LEDs to ±0.043. The error is easy; the channels cannot see the recipe that sets it. Knowing each LED's pump halves the pooled miss, to ±0.119, and two blue channels can tell only one pump of three from the others.

The converter gives the red phosphor away
A camera's error under white LEDs built onto the Planckian locus is simple in what each LED is made of — its red phosphor and its colour temperature — and a small sensor's narrow departures cannot read the red phosphor. The proposal was a channel at 610 nm, where a garnet converter falls and a red phosphor rises, and the prediction that it reads the red-phosphor strength within a tenth of its range. Within a pump it reads nothing: ±0.36 to ±0.43 at 440 and 452 nm against a spread of ±0.36, and no red channel from 600 to 680 nm does better than ±0.22. The reason is the locus. To keep the white's colour, each step of red phosphor pushes the converter's peak shorter, by 29 to 55 nanometres from none to the most, and in every red channel the two changes cancel. What survives is the converter: the 600 nm departure reads its peak to ±5 nm. Read across all thirty LEDs at once, the converter gives the red phosphor away — ±0.12 — and the error read through that estimated recipe comes within ±0.08 at every pump, the 440 nm LEDs at ±0.078, half their own channel's miss.

Beside the locus the converter still gives the red away
On the Planckian locus, a white LED's red phosphor pushes its converter to a shorter peak, so an ambient sensor's 600 nm departure, which reads the converter, reads the red phosphor too — within ±0.12 of a spread of ±0.36 — and through it the camera's colour error within ±0.074 ΔE₀₀. Real LEDs are binned a few thousandths off the locus, and the prediction was that a Duv of 0.003 moves the converter about as far as a fifth of the red phosphor does, so that the line learned on the locus misreads off-locus LEDs by a fifth of the range and their error falls back to ±0.12. The converter moves under two nanometres. The line reads the off-locus LEDs' red within ±0.11 and ±0.12, as well as it reads the locus's own held out — with a bias of about a twentieth that follows the Duv's sign. The error reads a third to a half worse, ±0.096 and ±0.107, and most of that is the camera's error itself moving off the locus with nothing in the recipe changed.

Across a bin, the camera's error bends with the temperature
White LEDs a Duv of 0.003 off the Planckian locus have their red phosphor read by an ambient sensor as well as LEDs on it, and their camera colour error read a third to a half worse, because the error itself moves with the Duv. The prediction was that one Duv term in the error's line, learned over all eighty-nine LEDs, brings those beside the locus back to the locus's ±0.074 ΔE₀₀ and costs the locus LEDs nothing. One term buys little: ±0.109 below the locus and ±0.085 above. The error turns across the locus one way at 2,700 K and the other at 4,000 and 6,500 K, and bends most where it is warmest, so the Duv has to enter as a slope and a curve for each temperature — ten numbers a pump, not five — before both sides come back, to ±0.056 and ±0.048. That line then reads the locus LEDs at ±0.073, worse than the ±0.062 a line with no Duv in it manages once it is learned across the bin.

The bin's curve holds between its points and breaks beyond them
A camera's colour error under a white LED was read from an ambient sensor across a manufacturing bin by a line with a slope and a curve in Duv for each colour temperature, fitted at three Duv values — on the locus and 0.003 either side — and reading the LEDs beside the locus within ±0.056 and ±0.048 ΔE₀₀. A curve through three points passes through them whatever happens between them. The prediction was that 119 new LEDs built at ±0.0015 are read within ±0.06, and those at ±0.006 worse than ±0.10. Both halves hold: ±0.045 and ±0.043 inside, ±0.153 and ±0.161 outside. But the error's own mean course stays on its parabola within 0.02 out to ±0.006. The line's bend is not the error's: it is the gap the line leaves between the locus LEDs and the bin's edges, and a gap spent as a curvature quadruples at twice the distance.

A level for each temperature lets the curve be the error's
An error line with a slope and a curve in Duv for each colour temperature read white LEDs inside a manufacturing bin within ±0.045 ΔE₀₀ and LEDs at twice the bin's edge only within ±0.16, though the camera's own error stays on its parabola there. Its curve was borrowed: the line's shared terms could not place each temperature's level, and the square of the Duv absorbed the gap. The prediction was that one more number a pump, the square of the mireds, brings the locus LEDs within ±0.05 and those at ±0.006 within ±0.08. It brings the locus to ±0.025 — three times better than the locus-only line that started this run of essays — and the outer LEDs to ±0.049 and ±0.058. The curvature the line now implies at each temperature is the error's own within a fifth; what it leaves is the warm whites' scatter at the bin's edges.

The red phosphor tilts the warm whites and bends nothing
An error line with a level, a slope and a curve in Duv for each colour temperature reads white LEDs at 4,000 and 6,500 K within ±0.04 ΔE₀₀ across and beyond a manufacturing bin, but warm whites at twice the bin's edge only within ±0.087. The prediction was that the red phosphor sets a warm white's bend, so that one term more a pump — the square of the Duv times the estimated red — brings them within ±0.05. It moves them by a thousandth. The red phosphor enters the slope instead: the Duv times the red takes them to ±0.046 below the locus and ±0.067 above. And the rest points upstream. The first stage reads a warm white's red phosphor squeezed toward the middle of its range, the warm misses follow that misreading times the Duv at r = 0.79, and given the red each LED was built with the warm whites come within ±0.05 — though the same substitution doubles the error at 4,000 K.

The line had already undone the squeeze
An ambient sensor's first stage reads a 2,700 K white LED's red phosphor squeezed about a third toward the middle of its range, and the camera-error line's warm misses outside the bin follow that misreading times the Duv. The prediction was that giving the first stage the Duv times its 600 nm departure and times the mireds would undo the squeeze. It changes nothing: the squeeze belongs to the temperature, and a level and a departure slope for each temperature read the warm red four times better, within ±0.035. But the eleven-term error line does not move — no warm LED by more than 0.006 — because at one temperature a squeeze is a rescaling its red and red-times-mireds terms had already undone. Only the red-slope line, whose one coefficient a pump spans three temperatures, gains: to ±0.034 below the locus, within 0.002 of the red known. And the cold whites pay for it.

Two estimates of one red each read their own end
Two first stages read a white LED's red phosphor from an ambient sensor: one squeezes the warm whites' red a third toward the middle, the other reads it four times better, and a camera-error line with a red slope prefers the first for cold whites and the second for warm. The prediction was that a line handed both — the eleven-term line on the squeezed estimate, the red slope on the faithful one — keeps each end's gain. It does, within 0.004 at the cold end. But the second estimate is not needed: the squeezed red alone, its red slope multiplied by the mireds, reads every LED within a ten-thousandth of the split line. And the two estimates' difference is worth a term of its own. Added to the line, it reads the cold whites within ±0.016 at every Duv and on the locus within a thousandth, and moves the warm whites and the middle by nothing.
What it takes to deliver it
A colour that stays where it was measured is nobody's problem. This is the apparatus that carries one to somebody else — ink on a sheet, a profile, a rendering intent, a proof, and a room — and every stage of it is a map that loses something, chosen deliberately.
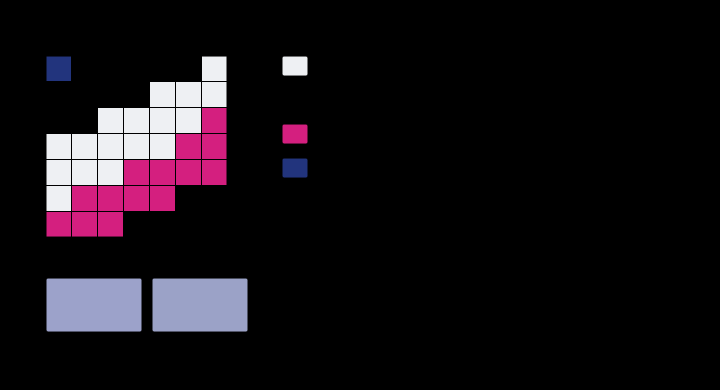
A halftone is not a mixture
Forty per cent cyan and thirty per cent magenta are not stirred together anywhere. They are laid down as dots, and the sheet is a mosaic of four fully-inked regions in proportions the two coverages fix — which is why the colour is an area average of four spectra rather than a blend of two, and why it lands nowhere near where mixing would put it.
A dot is larger than it was asked to be
Two quite different things make a printed midtone darker than its coverage says — ink spreading under pressure, and light scattering sideways inside the paper. Both bend the tone curve the same way and neither touches its ends, so the measurement every press is characterised by cannot say which happened. A patch that nobody measures can.