Every essay — page 35
What light is What the eye does Matching and measuring Difference and uniformity What the brain does What a scene does What a camera does Where the model breaks What it takes to deliver it
SeriesObserversNamed objectsRefutationsSearch
What a camera does
A camera is three functions of wavelength collapsing a spectrum onto three numbers, which is what an eye is — and they are different three functions. Everything a photograph can and cannot establish about colour follows from that, and from the fact that silicon sees three hundred nanometres past where anybody is looking.

Two matrices do not reach a white LED
A camera profile's two matrices, blended by the scene's colour temperature, are as good as a matrix fitted anywhere along daylight. Under a white LED or a fluorescent tube the same blend leaves colours twice as far off as a matrix fitted under that lamp, and no weight inside the profile's range repairs it. What decides it is not how far the lamp sits from the Planckian locus — a triphosphor tube sits nearly on it and fares worst — but whether its spectrum has lines in it, which a white balance reading cannot see.

Filling in a highlight is a claim about the surface
A converter that rebuilds a clipped channel has to say what the highlight was. A matt surface over-exposed keeps its own colour, and filling the lost channel from that colour is exact. A glossy highlight is the surface's colour plus a reflection of the lamp, and the same fill leaves it 7.6 colour differences too colourful — while a fill that solves for surface and lamp is exact. Neither works once two channels are clipped, and a tungsten lamp keeps a highlight in the one-channel band more than twice as long as daylight does.

Flicker sorts lamps the wrong way
A camera cannot see a spectral line in its own white, so the essay on the two-matrix profile named the classifiers a device might have instead, and the first of them was flicker. Flicker is measurable, and it measures the wrong thing. It sorts lamps by how their power is delivered while the matrix needs them sorted by how their spectrum is shaped, and the two are independent: a white LED on a constant driver is perfectly steady and strongly structured, and it is what most indoor photographs are lit by.

The converter can choose except where it matters
A converter rebuilding a clipped highlight has to say whether the surface was matt and over-exposed or glossy and carrying a reflection, and the evidence is whether its raw chromaticity slides towards the lamp's on the way up. Read through the sensor's own noise, the slide is clear on most of the chart from the few tens of pixels a specular highlight holds — and on the surfaces where it takes half a frame, confusing the two models costs more than the median. A ratio cannot see a common scale, and an exposure supplies one.

Four places to clamp are two pipelines
The essay on clipped noise ended on a procedure: a black frame and a dim grey card at a high amplification would place each raw converter's clamp. A procedure is a claim that a measurement identifies something, and this one identifies less than it looks. A clamp at zero commutes with the white balance and with the tone curve and not with the colour matrix, so the four positions are two pipelines — and the measurement separates them, on a card at half a per cent of white rather than on the black frame.

Two lamps decide what one lamp could not
Under one lamp a handful of surfaces cannot tell a glossy highlight from a matt over-exposure without most of a frame, because there the two differ by a scale a ratio cannot see. In a room lit evenly by a 3000 K lamp and daylight, every surface on the chart is decided from ten pixels. A body can sit at one lamp's white, not at two, and the rescue holds only while the second lamp carries a fifth of the light and its white sits far enough from the first.

Two sensors disagree about deep red, not lines
A phone's ambient-light sensor and its camera read the same lamp differently, and the difference sorts fourteen lamps into smooth and structured without a single mistake — where flicker made five. It is not reading their lines. Almost all of it comes from the sensor's clear channel collecting deep red the camera's infrared cut throws away, so daylight with its far red trimmed is called structured and a white LED with a far-red emitter is called smooth.

A narrow channel has to be read on its own
An ambient sensor with a clear channel tells structured lamps from smooth ones by reading deep red, and one without it reads structure but breaks at one per cent of calibration error. A narrow fourth channel between the camera's peaks was proposed to have both. Pooled into the sensor's disagreement with the camera, it reads structure and breaks at one and a quarter per cent — no better than the design it was meant to rescue. Read on its own, as its departure from what the camera predicts for it, a channel at 450 nm holds to four per cent, the clear channel's figure, and far red does not move it.

One row for every lamp costs the lamps that lose least
A corner correction fitted under one lamp is right under that lamp and can be badly wrong under another, so a converter unsure of its lamp was offered a single row fitted under several at once. Pooled over four lamps, one row holds every lamp's corner between 1.33 and 1.56 colour differences — no lamp worse than a grey-card map, and none near the 4.91 a wrong row can leave. The price falls on the white LED and the fluorescent tube, which it leaves four times worse than their own rows, because they lose the least red at the corner and the pooled row is built to repair the lamps that lose the most. Two rows, one per class of lamp, keep almost all of both.
What it takes to deliver it
A colour that stays where it was measured is nobody's problem. This is the apparatus that carries one to somebody else — ink on a sheet, a profile, a rendering intent, a proof, and a room — and every stage of it is a map that loses something, chosen deliberately.
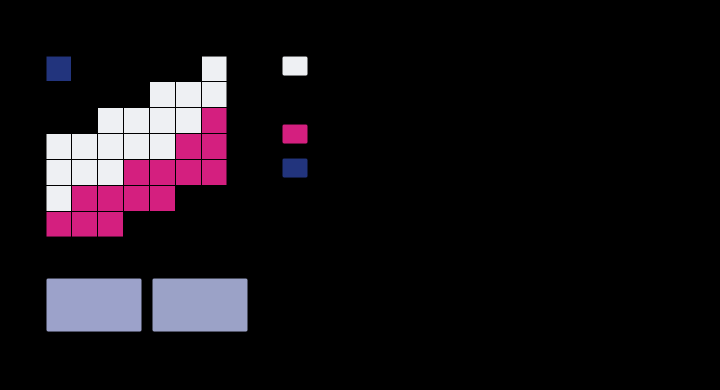
A halftone is not a mixture
Forty per cent cyan and thirty per cent magenta are not stirred together anywhere. They are laid down as dots, and the sheet is a mosaic of four fully-inked regions in proportions the two coverages fix — which is why the colour is an area average of four spectra rather than a blend of two, and why it lands nowhere near where mixing would put it.
A dot is larger than it was asked to be
Two quite different things make a printed midtone darker than its coverage says — ink spreading under pressure, and light scattering sideways inside the paper. Both bend the tone curve the same way and neither touches its ends, so the measurement every press is characterised by cannot say which happened. A patch that nobody measures can.
Neither gamut contains the other
Converting a picture to CMYK is described everywhere as a reduction, as though the press were a smaller version of the screen. Measured as solids, the press reaches eleven per cent of its volume outside sRGB while sRGB reaches fifty-four per cent of its volume outside the press — and in the cyans the press wins by seventy per cent of chroma.